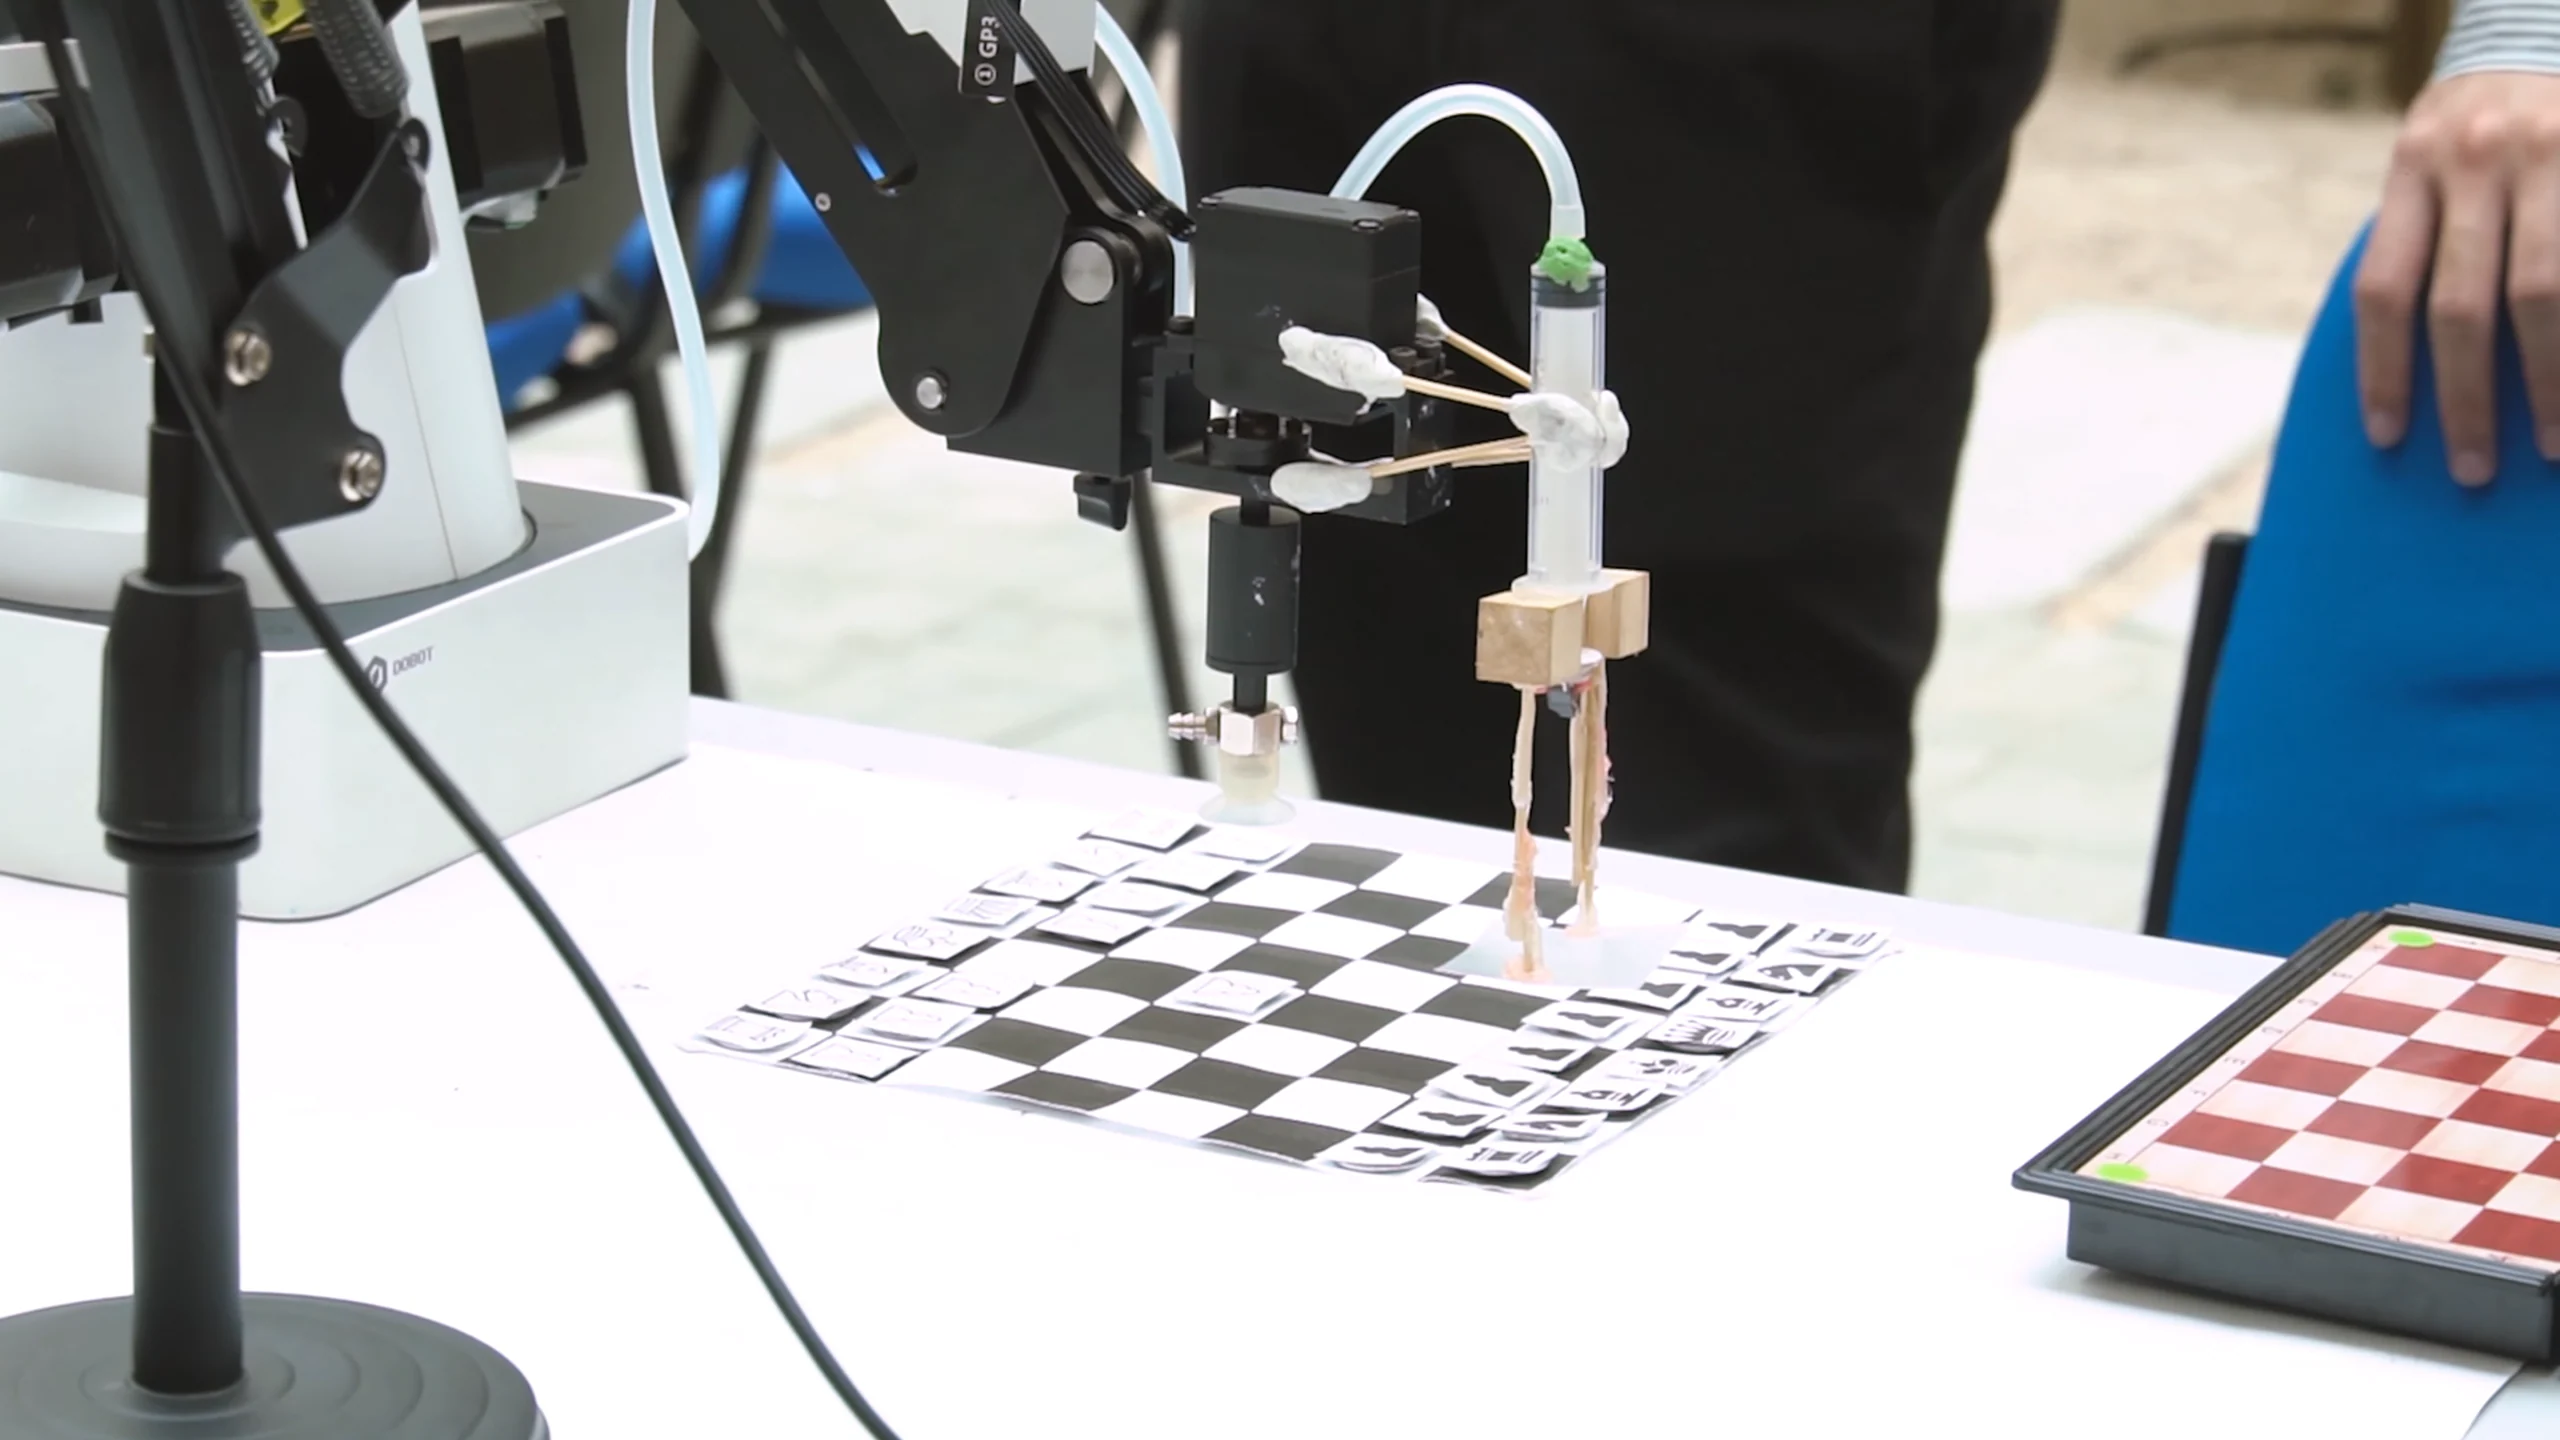
Dobot Chess Playing Robot Arm
Bridging Computer Vision and Robotics on a Standard Chessboard
“Most chess engines live inside a screen. This one plays on the table in front of you.”
Concept
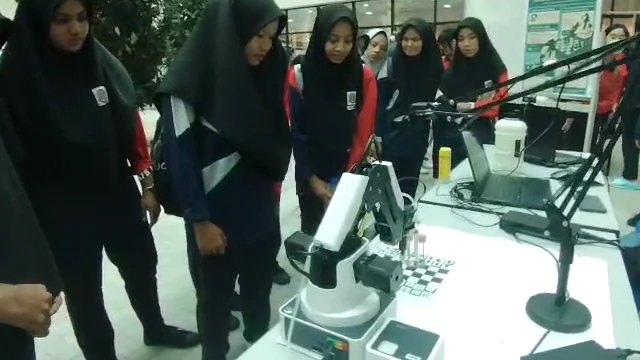
The Chess-Playing Robot is an autonomous system that can observe a physical chessboard, determine the current game state using computer vision, calculate a move using a chess engine, and then physically execute that move using a Dobot Mg400 robotic arm. The challenge was not writing a chess engine (powerful ones exist), but bridging the gap between a digital decision and a physical action on a real board.
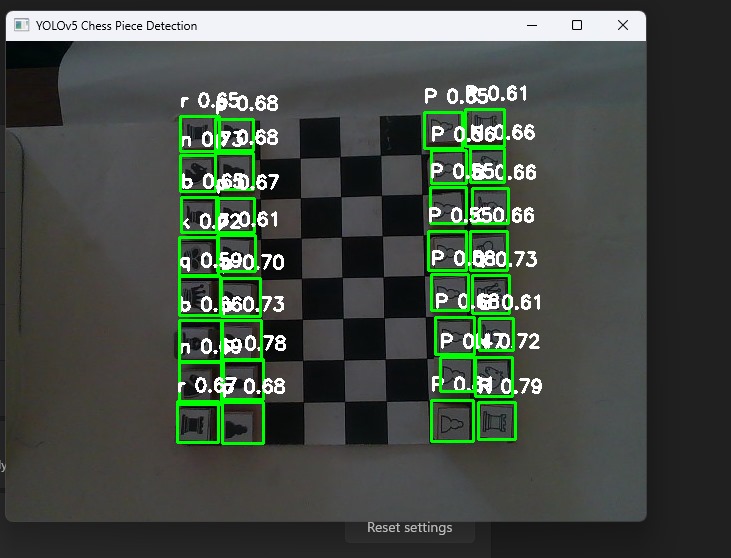
Board State Recognition
Recognising the state of a physical chessboard in real time is harder than it sounds. Pieces cast shadows, lighting shifts, and pieces look different from different angles. I trained a YOLO model on a custom dataset of chessboard images labelled with piece types and positions. The model processes each camera frame, identifies every piece on the board, and maps their positions to standard chess notation, producing a machine-readable board state that can be fed directly to a chess engine.
The Physical Bridge
Once the chess engine calculates an optimal move, the system translates the move into physical coordinates corresponding to their positions on the real board. The Dobot robotic arm receives these coordinates and executes the move: picking up a piece from its source square and placing it on the destination square. Handling piece captures (removing a piece from the board before placing another) required sequencing multiple arm movements reliably.
Integration Challenges
The hardest part of this project was reliability. Each component (the camera, the detection model, the chess engine, and the arm) had to work correctly in sequence for every single move, with no room for compounding errors. Calibration between camera space and robot space needed to be precise to within millimetres. The result was a system that could play a complete game of chess autonomously, entirely in the physical world.
Project Gallery
7 items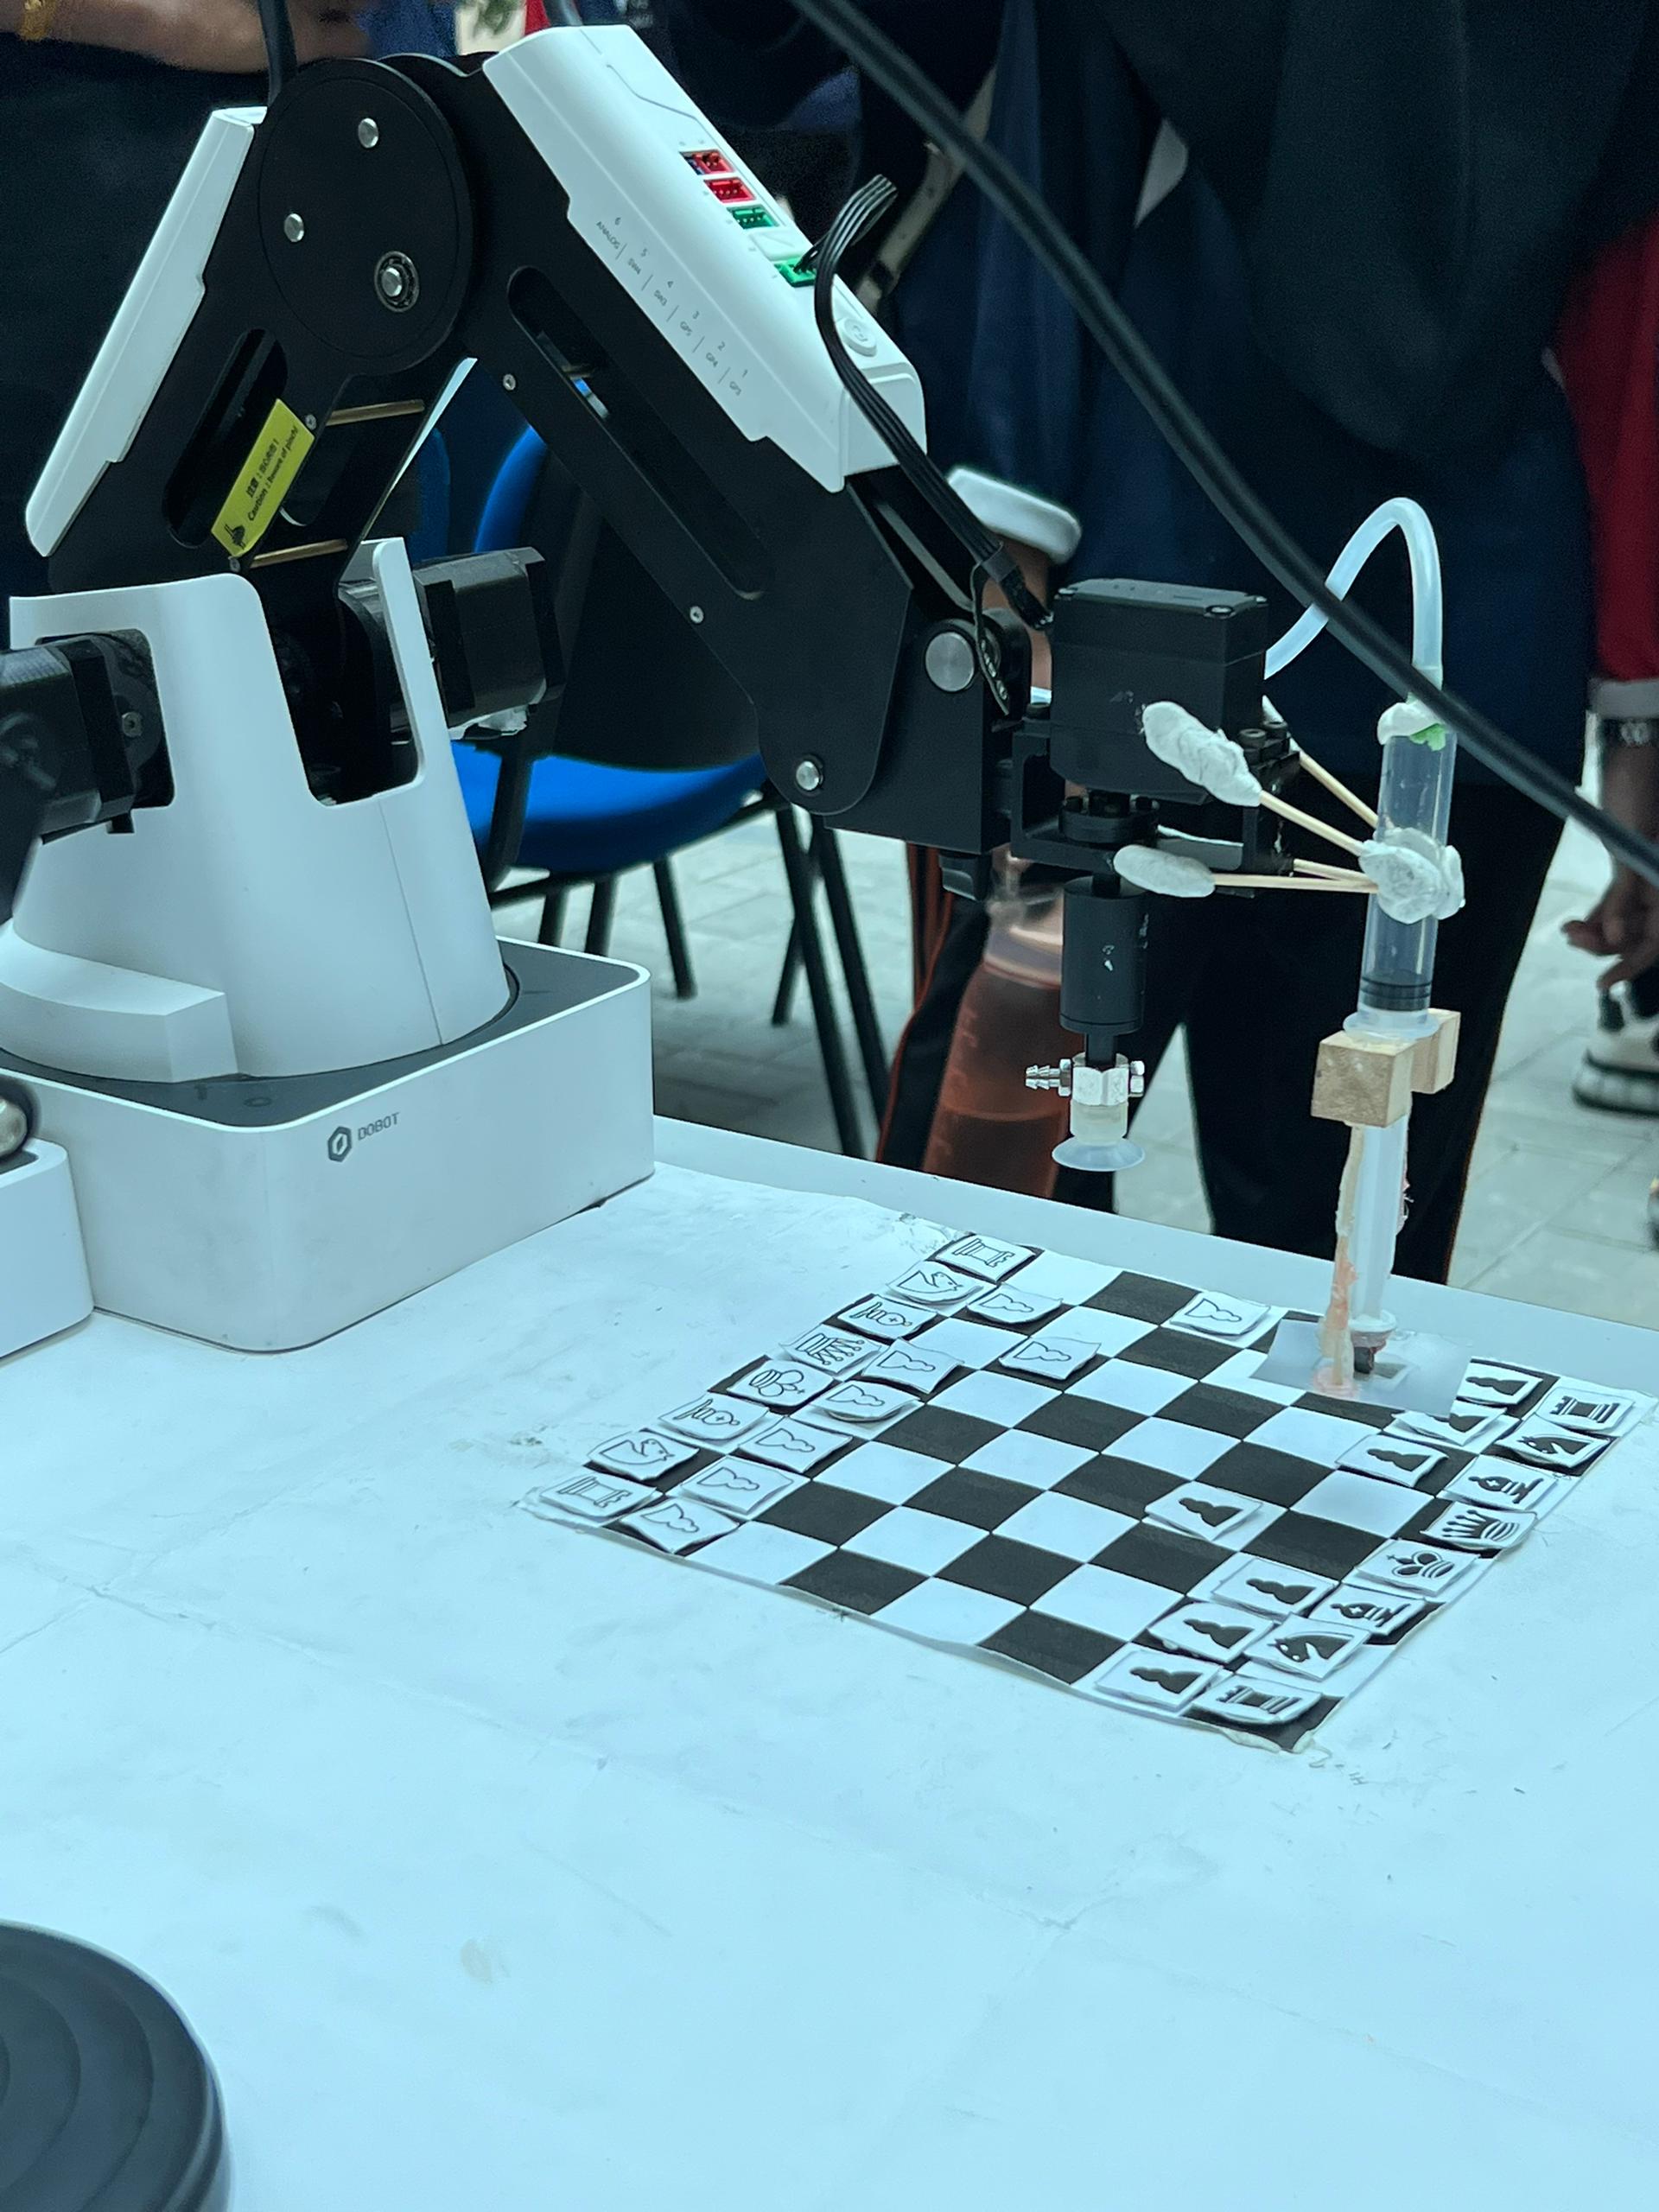
Explore More Projects
Swipe or click arrows to see other work
 View projectanalyzing project #01
 View projectanalyzing project #02
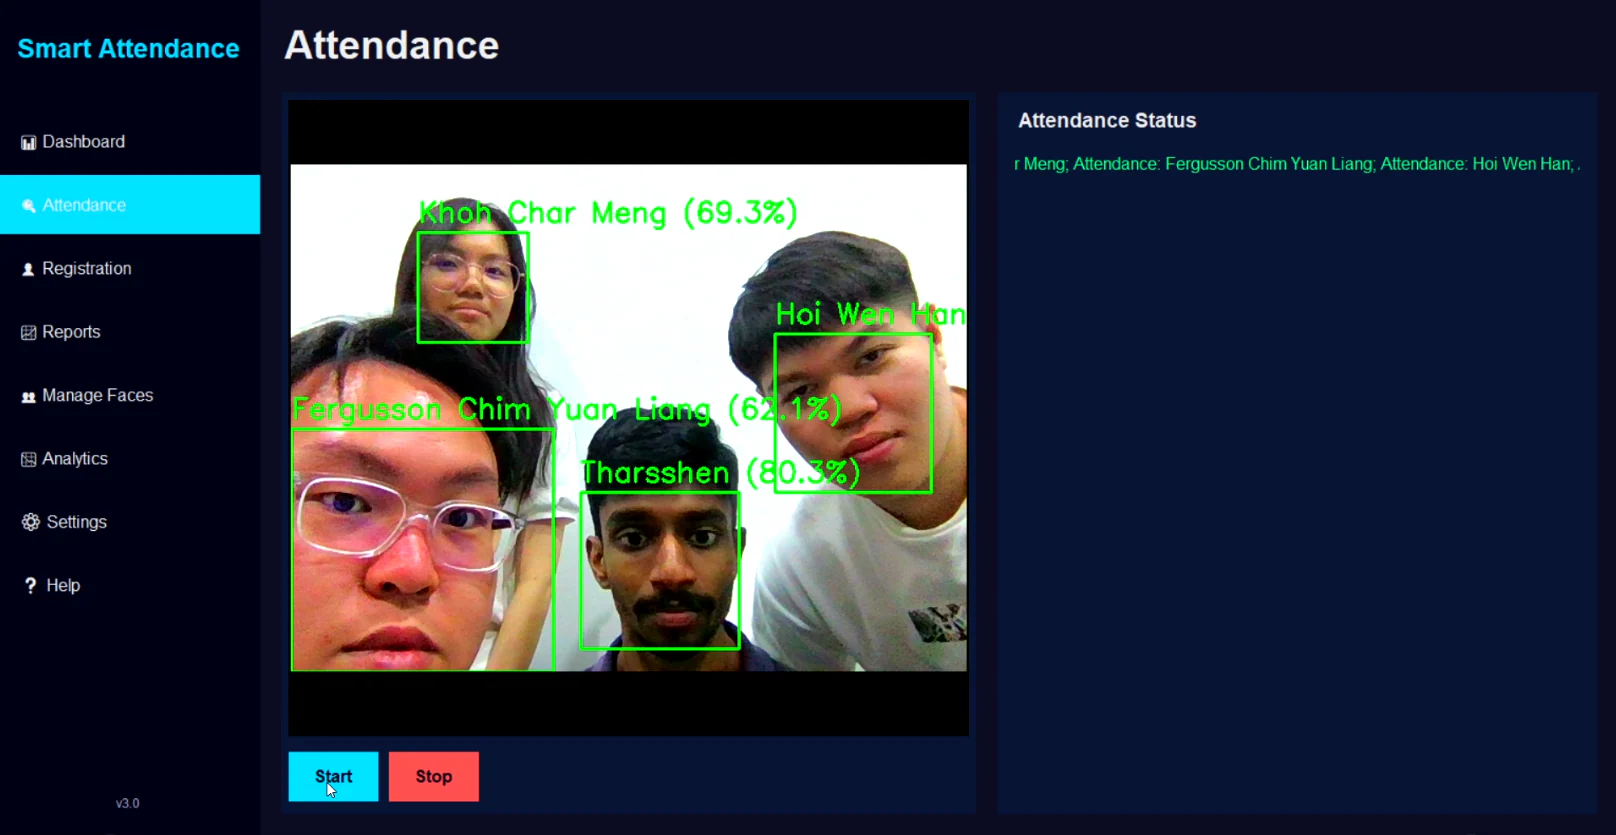 View projectanalyzing project #04
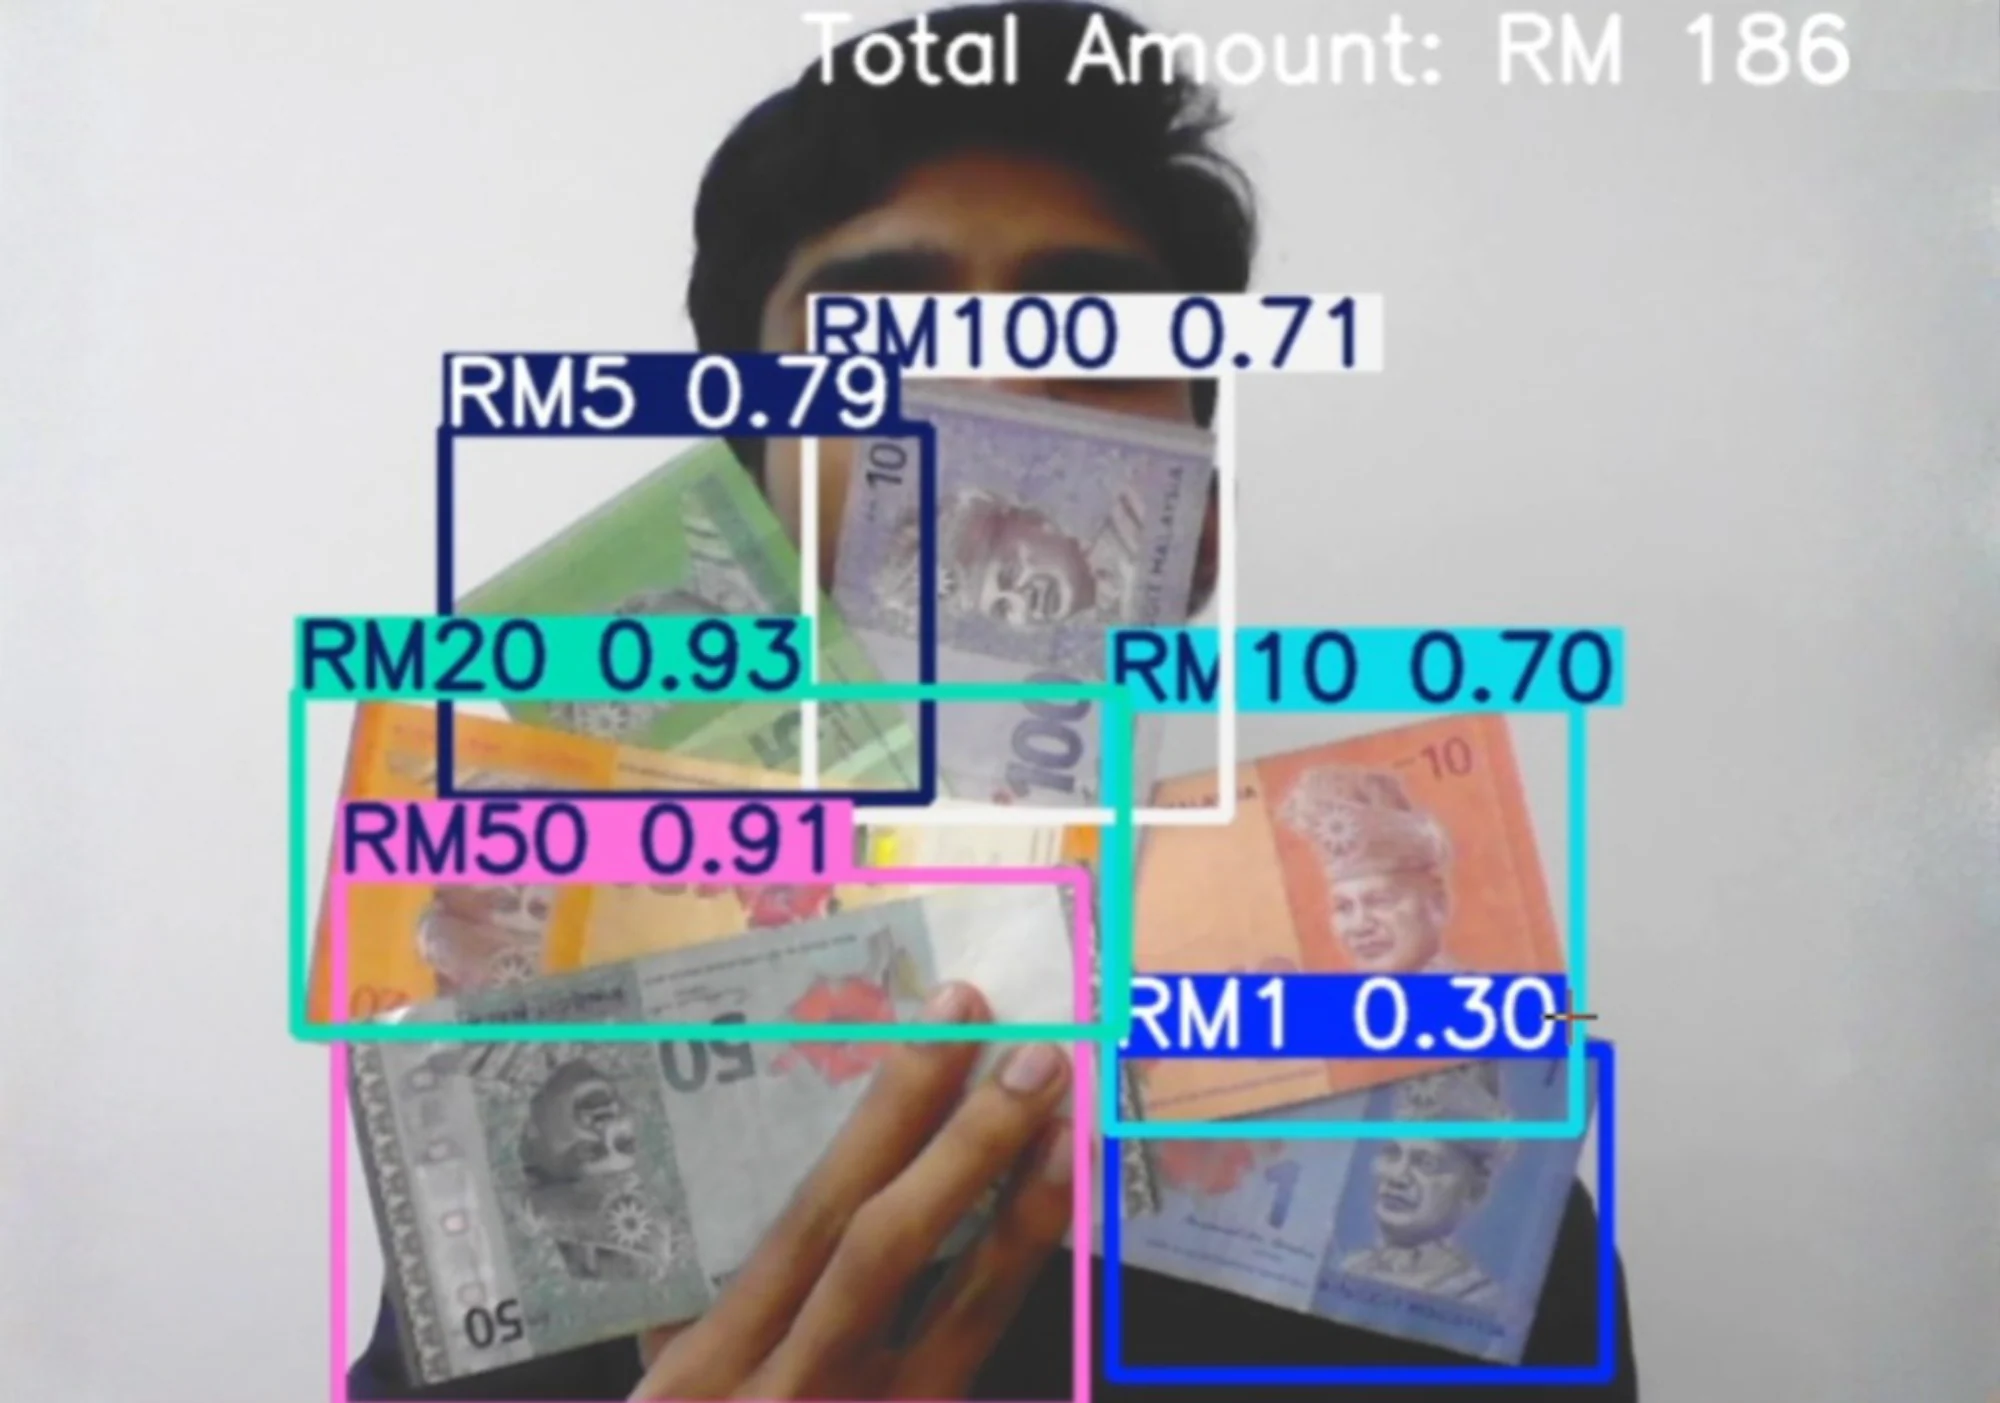 View projectanalyzing project #05
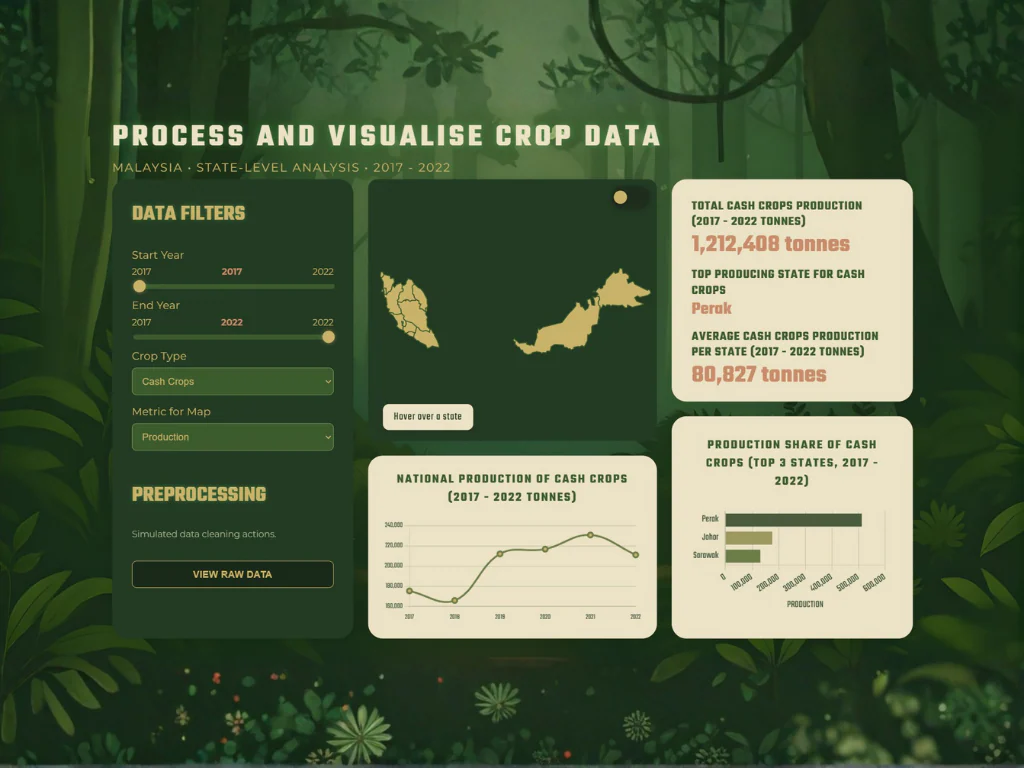 View projectanalyzing project #06
 View projectanalyzing project #07
 View projectanalyzing project #08
 View projectanalyzing project #09
 View projectanalyzing project #10
 View projectanalyzing project #11
 View projectanalyzing project #12
 View projectanalyzing project #13
 View projectanalyzing project #14
 View projectanalyzing project #15
 View projectanalyzing project #16
 View projectanalyzing project #17
 View projectanalyzing project #18